
Carbon + Zig for next-gen robotics engines
A deep robotics engine research track: a Zig real-time core for deterministic control loops and embedded targets, with Carbon exploring a modern successor path for the C++ robotics stack it must interoperate with.
Zig, Carbon Language, C++ interop, Robotics, Real-time, Embedded
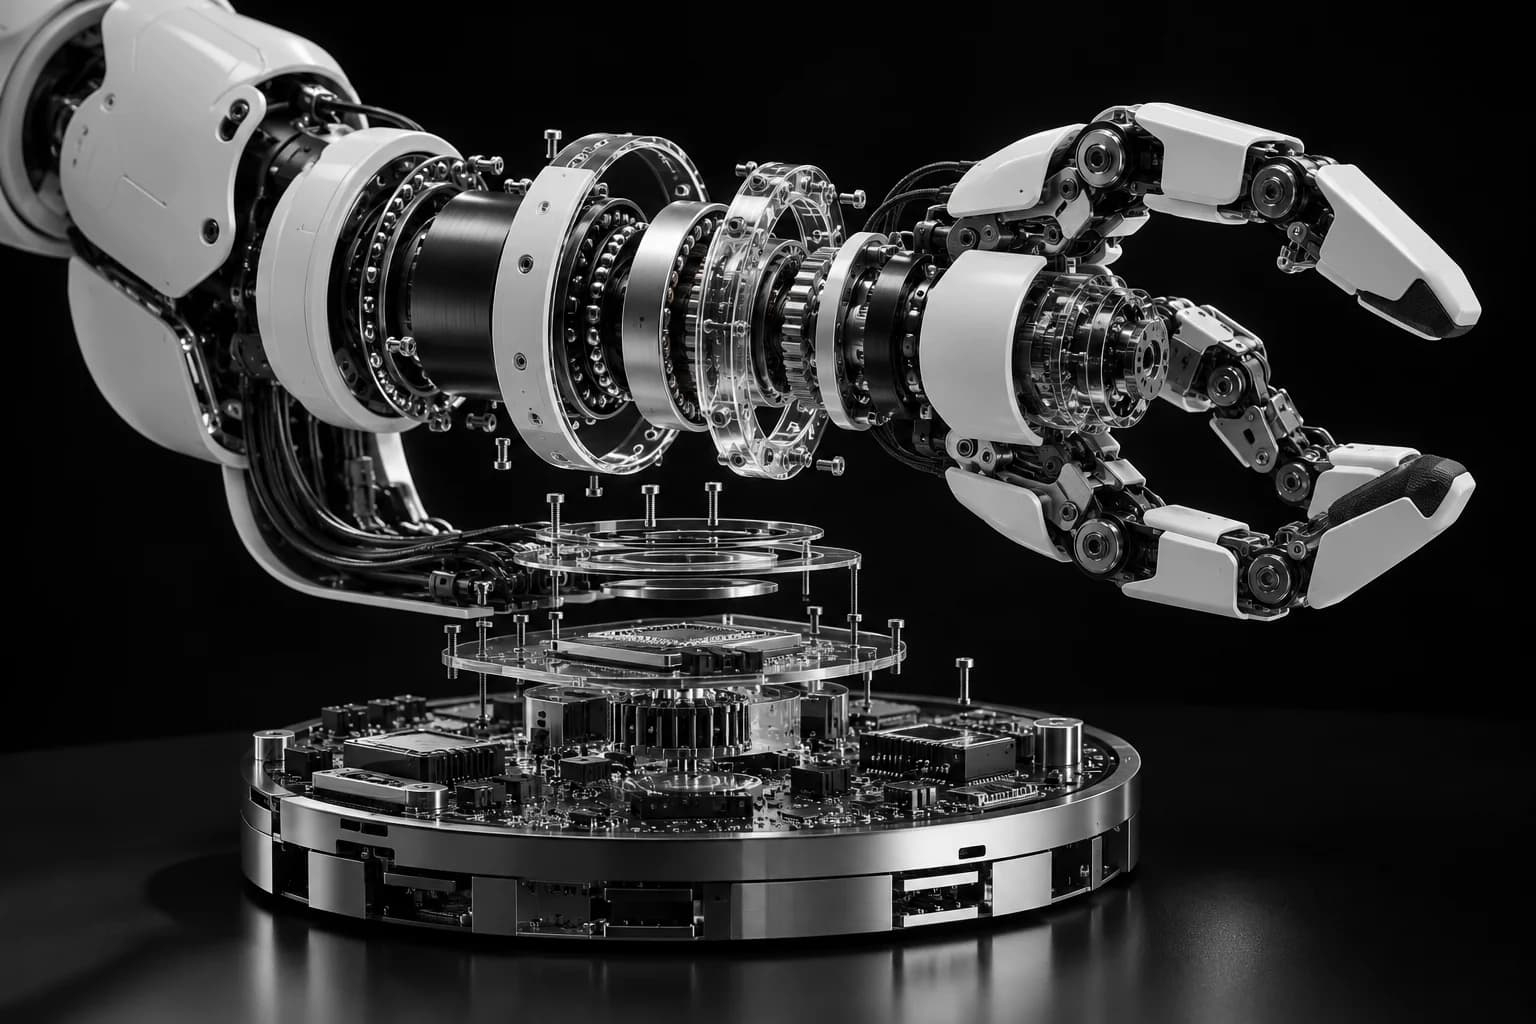
A research track for the next generation of robotics engines: the low-level runtime that turns sensor data into motor commands, with hard real-time guarantees. Zig powers the deterministic core and embedded targets; Carbon, Google’s experimental successor to C++, is evaluated as the modern path for the large C++ robotics ecosystem the engine has to live alongside.
What I’ll build
- Zig real-time control loop with fixed-size allocators and no hidden allocations or control flow.
- Motor, encoder, and IMU drivers cross-compiled for ARM Cortex-M, RISC-V, and Linux SBCs from one codebase.
- Sensor fusion and state estimation with bounded latency per tick.
- Stable C ABI so planners, simulators, and ROS 2 nodes can call the core safely.
- Carbon prototypes of planning and kinematics modules that interoperate with existing C++ libraries.
- Hardware-in-the-loop test rig with timing histograms and jitter budgets in CI.
- Safety layer: watchdogs, torque limits, and an emergency-stop path independent of the planner.
Architecture
The Zig core owns the control loop, drivers, and memory, and exposes a small C ABI. Above it, motion planning and kinematics run in C++ today, using libraries such as Eigen and ROS 2, while Carbon modules are introduced where its bidirectional C++ interoperability allows a gradual migration. Carbon is still experimental, so it stays on the research side of the engine until the toolchain is production-ready, and every Carbon module keeps a C++ fallback.
Stack: Zig · Carbon Language (experimental) · C++20 · C ABI · ROS 2 · Eigen · ARM Cortex-M · RISC-V · Linux RT
Roadmap
- Zig control-loop core with drivers for one robot arm and measured jitter budgets.
- C ABI bindings and a ROS 2 bridge node.
- Carbon–C++ interop prototypes for kinematics and trajectory planning.
- Hardware-in-the-loop CI and a published latency and safety report.
- Open reference engine for mobile robots and manipulators.
Interested? Robotics startups, hardware teams, and systems engineers — email contact@imaddhin.com.